
Running, not rendered.
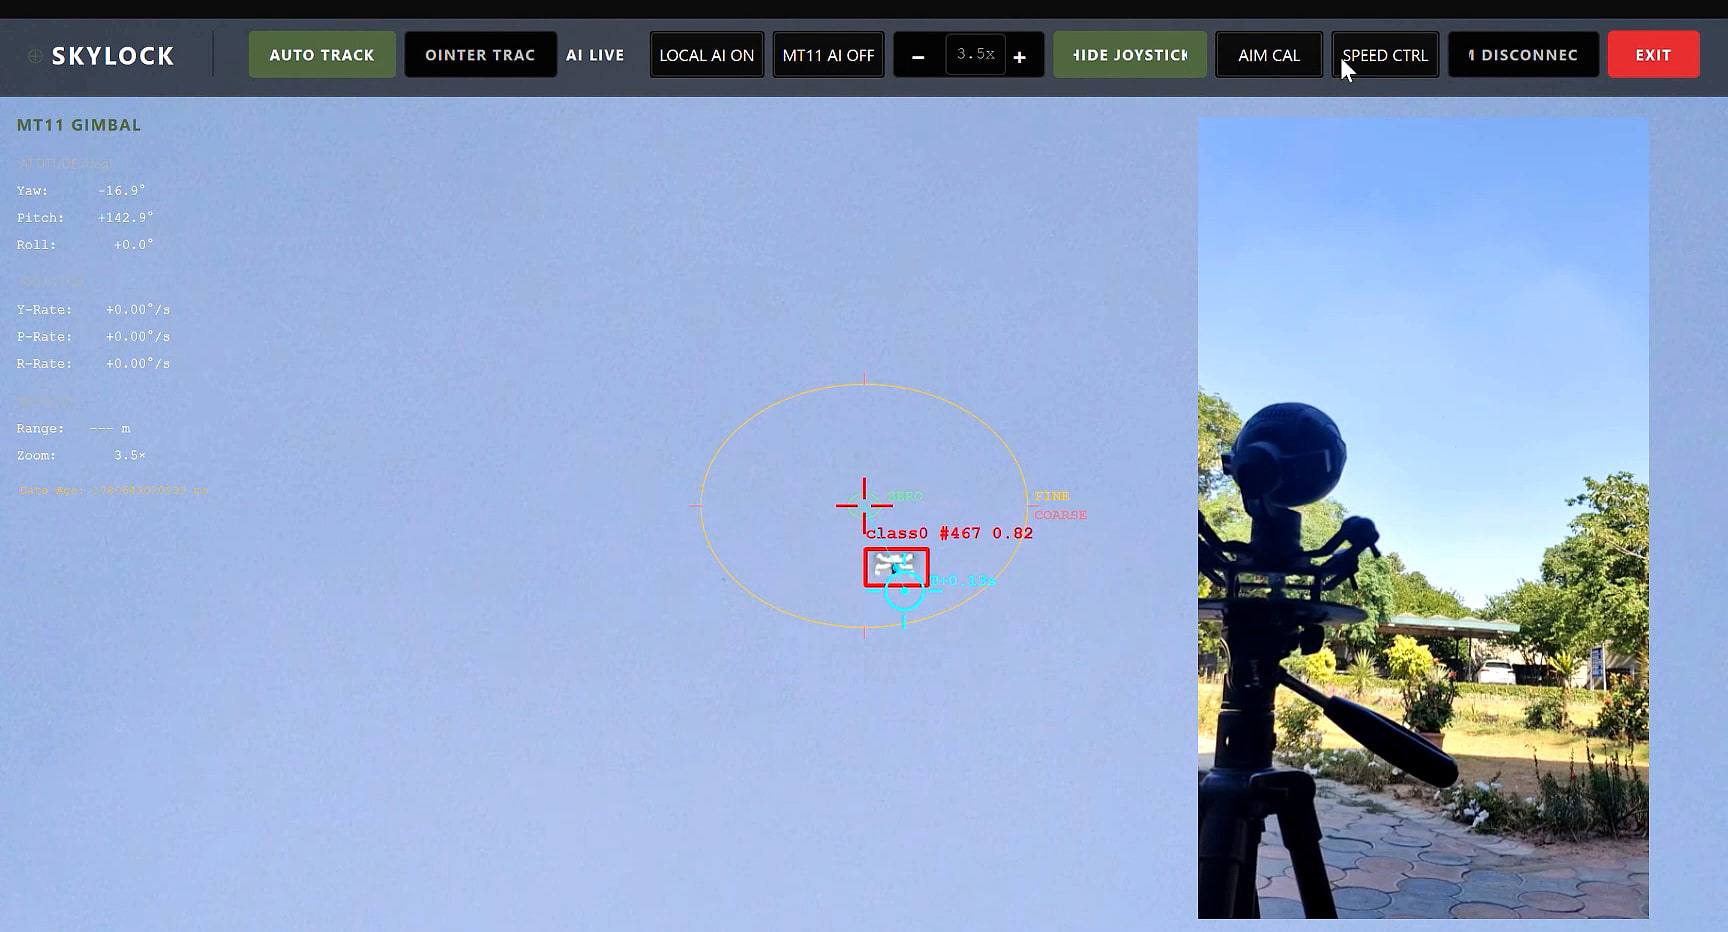
Real systems, with what they do, and clips of them running. 7 projects across drone tracking, robotics, wearables and factory software.
Switch inputs on to see the work that used every one of them.
All 7 projects.
The projects
Case study, assistive robotics
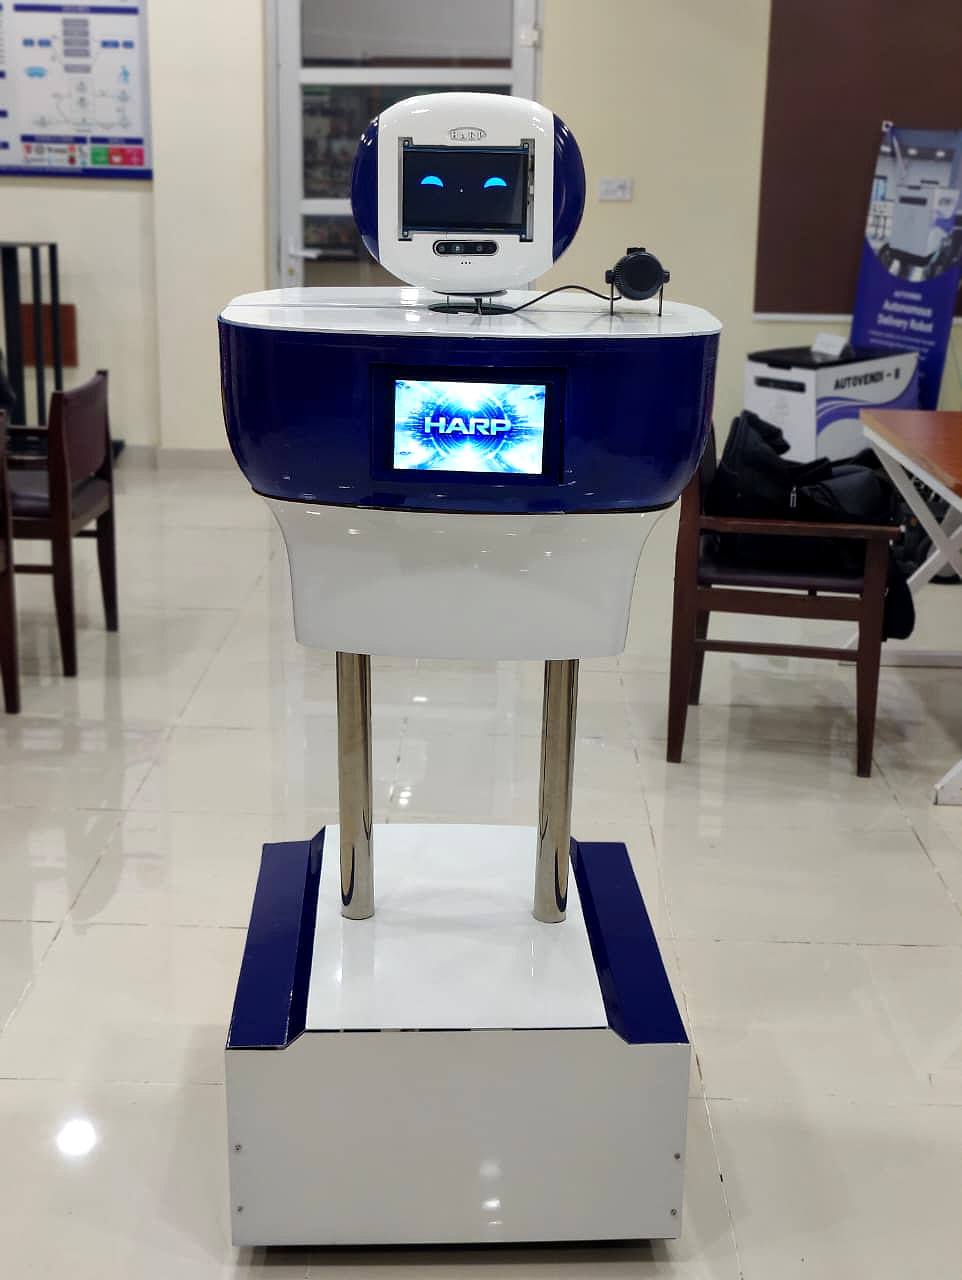
HARP
Navigates a mapped building, tracks faces and holds a conversation with an onboard language model, built around a Raspberry Pi 5.
A hardware, C AI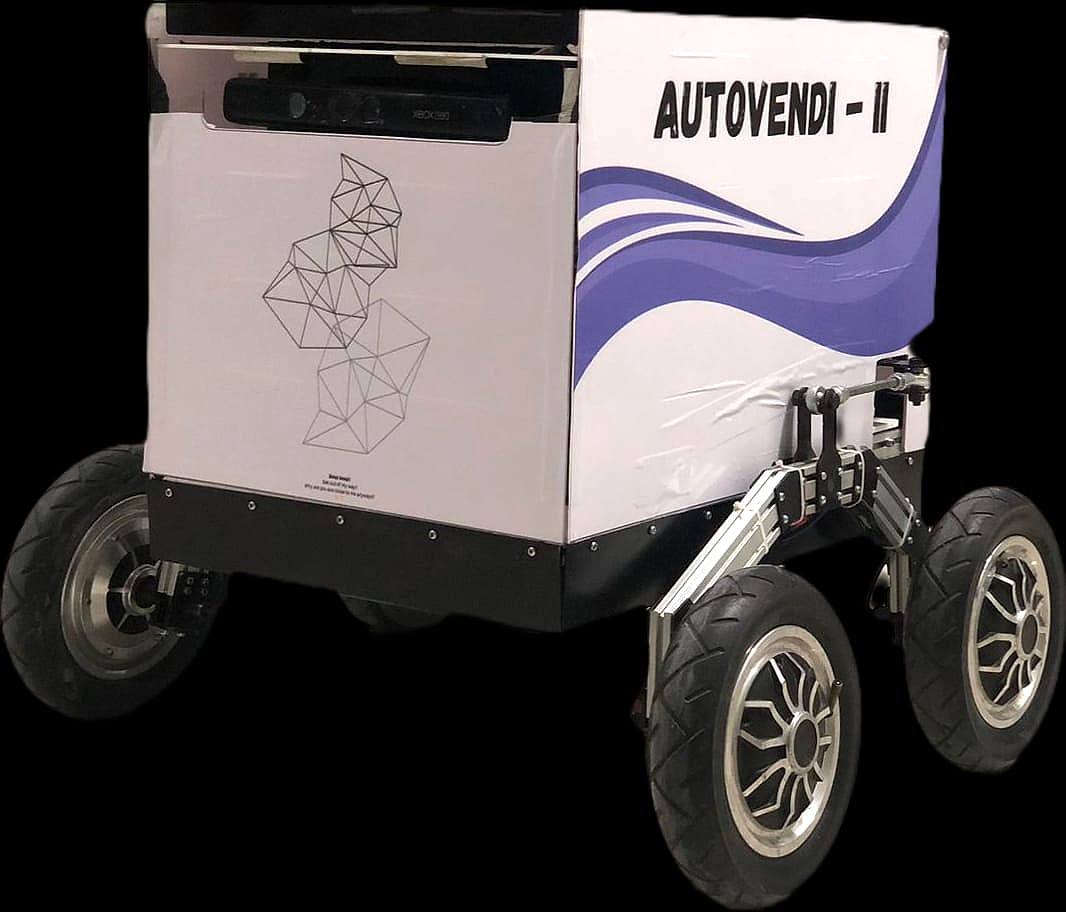
Case study, last-mile logistics
Auto Vendi
Maps its route, avoids obstacles and delivers in a locked compartment that the phone app releases.
A hardware, B software, C AICase study, manufacturing
Quality inspection platform
Logs defects, marks fault locations and exports to Excel and PDF.
B software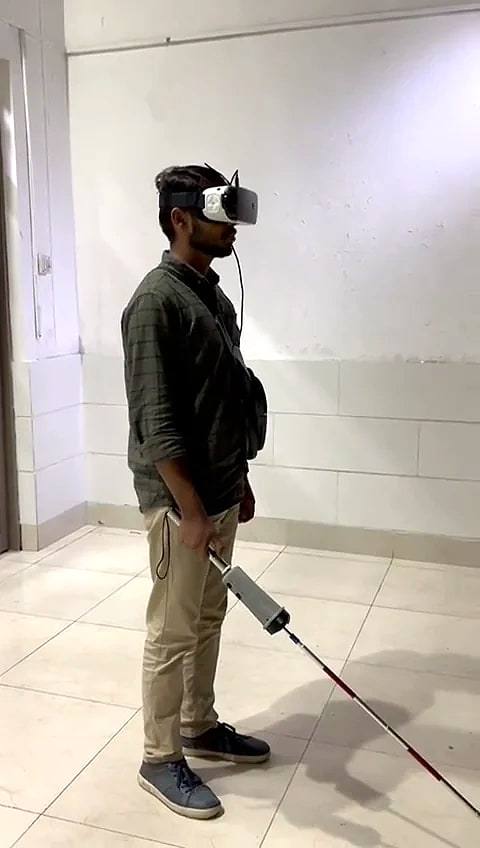
Prototype, assistive technology
SceneScribe
Describes what the camera sees, in answer to the wearer's own question, through earphones.
A hardware, B software, C AI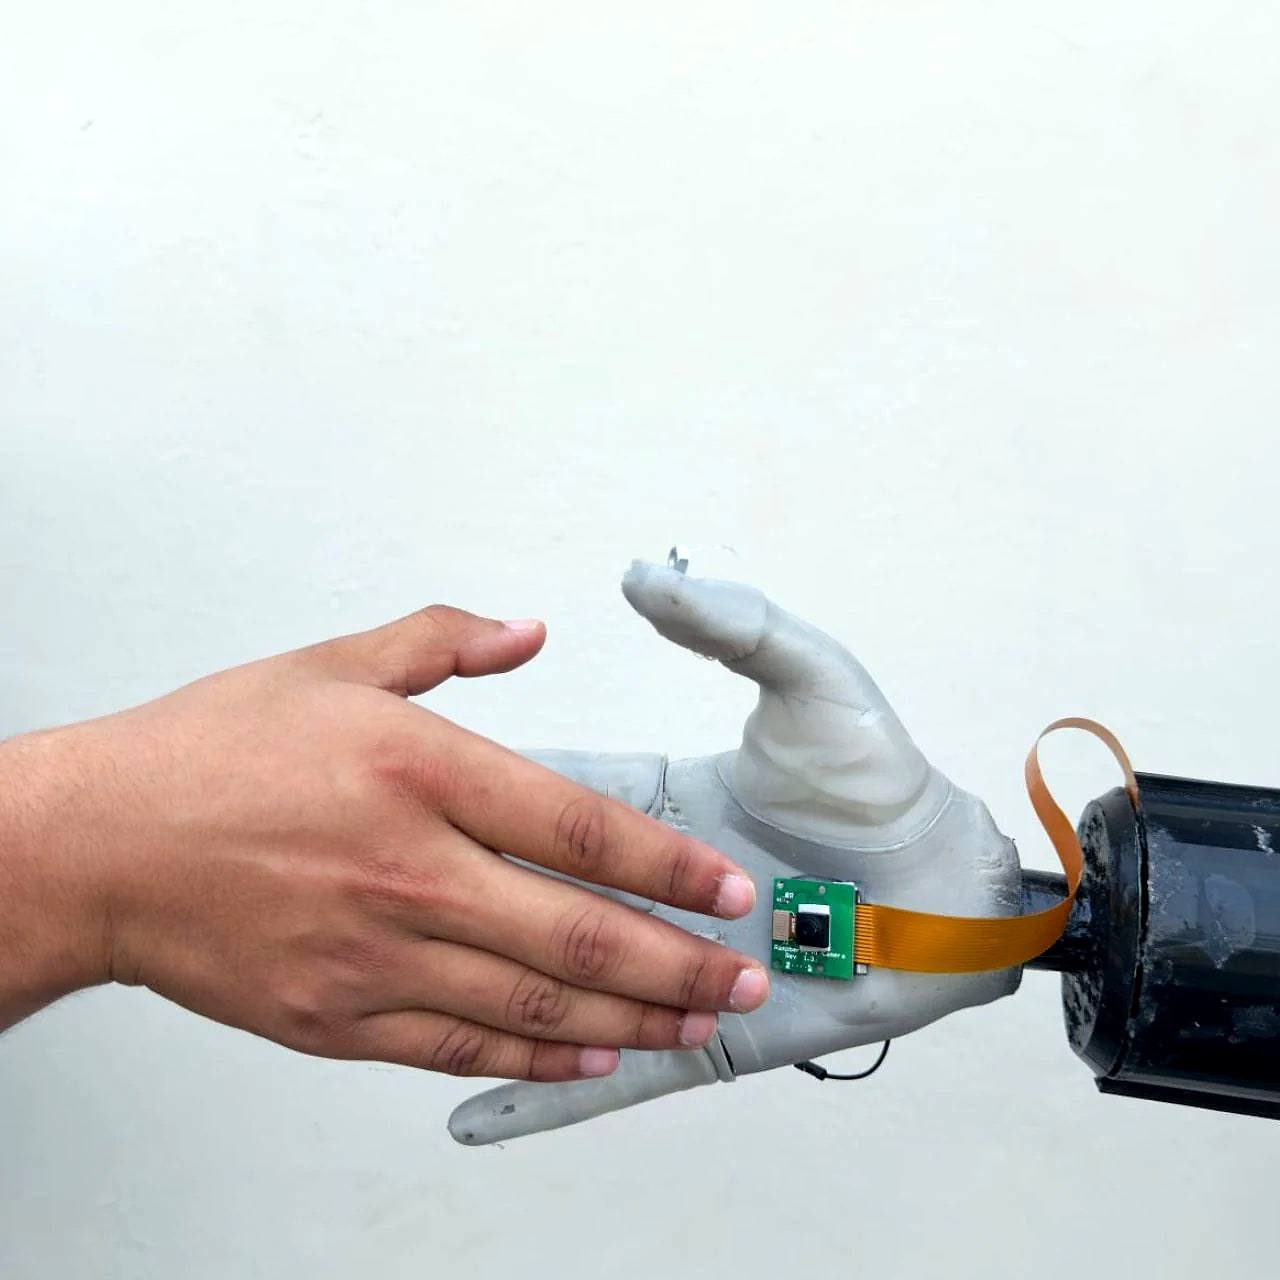
Research prototype, assistive robotics
ReFlex
Reads forearm muscle signals, chooses a pinch or tripod grip from what the palm camera sees, and stops each finger on encoder feedback.
A hardware, C AI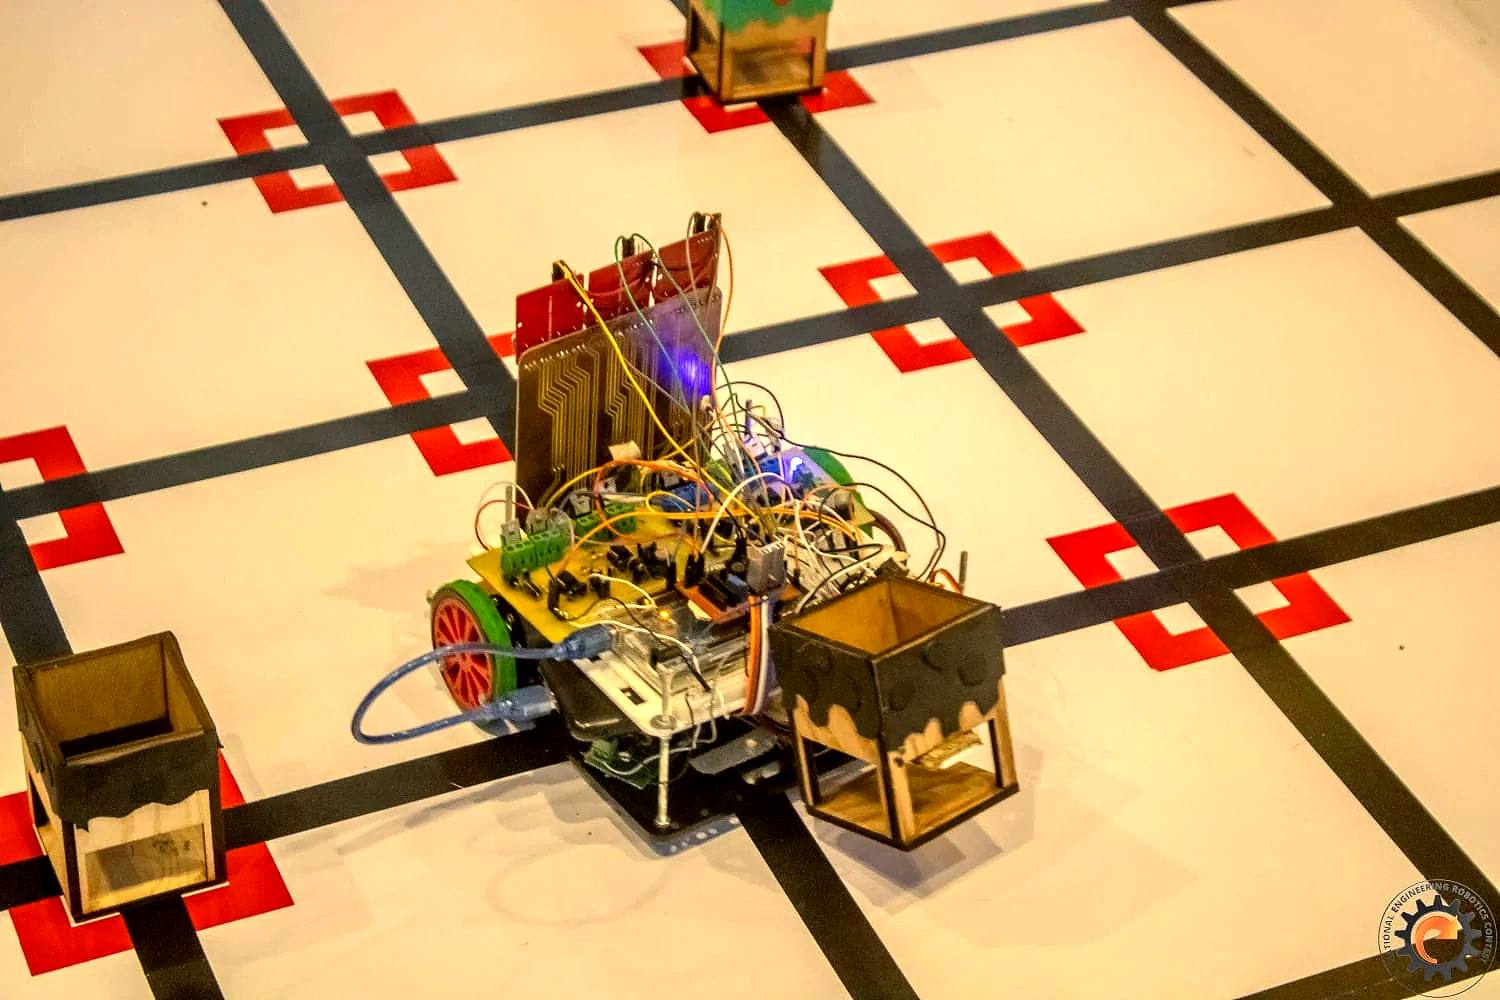
Competition robot
Tree-planting robot
Follows the arena's lines, plans on a grid and places blocks with its own mechanism.
A hardwareNo published project uses every input you switched on yet. Growth results appear here once a client agrees to publish them.
From the log
Short clips of the work running, with what each one shows.
Tell us what has to work.
One sentence is enough. An engineer will reply.